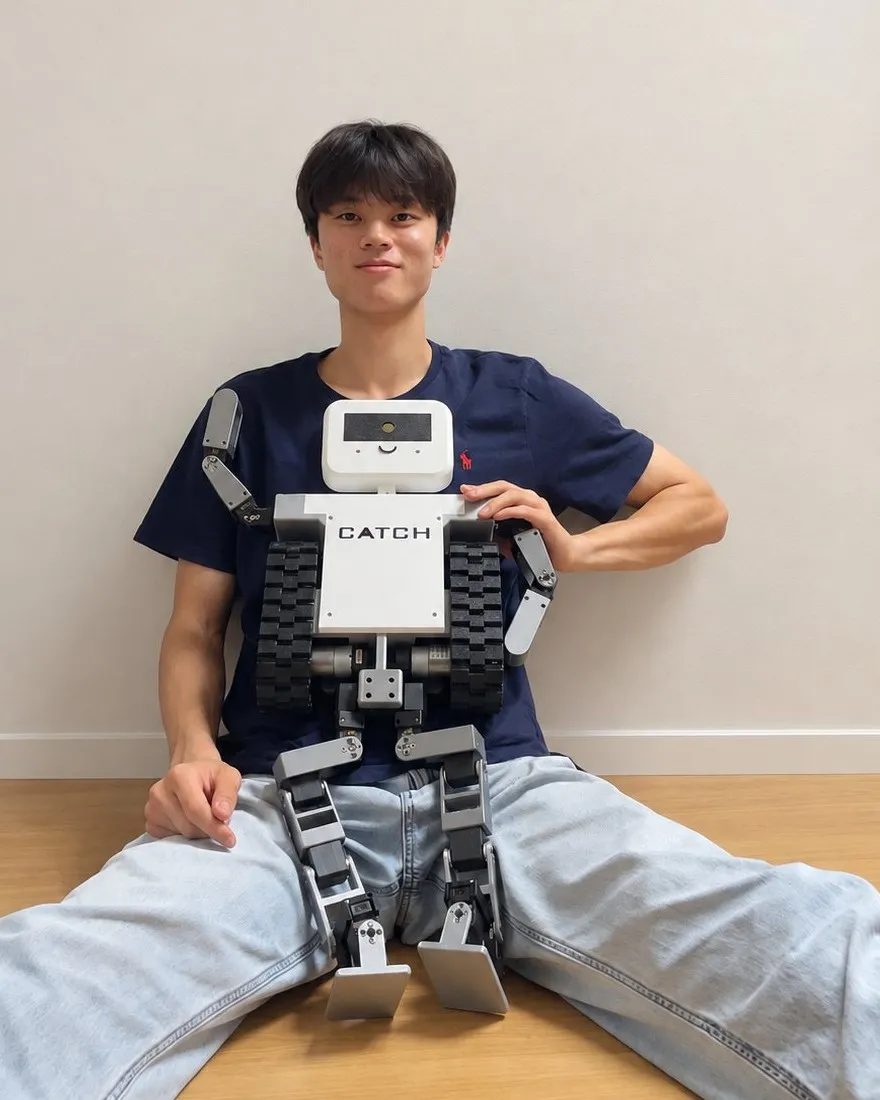
Yobel Sungkook Lee
Robotics ResearcherB.S. Mechanical Engineering, Sungkyunkwan University
I want to build many kinds of robots, each with its own character and purpose, that people want to have around and can rely on. A robot's character comes from both its body and how it moves, yet the two are usually designed separately. I want to design them together, using morphology-conditioned policies that can control many different bodies, so a new design can be tested in simulation before it is built.
So far, I've designed and built a worm-inspired colonoscopy robot and a compact pipe-inspection robot, and studied reinforcement-learning-based locomotion for legged robots. I'm now building CATCH, a small transformable humanoid designed to take different forms for different tasks: moving low on torso-mounted tracks or standing upright to reach out and interact.
Email: yobel.s.lee [at] gmail [dot] com
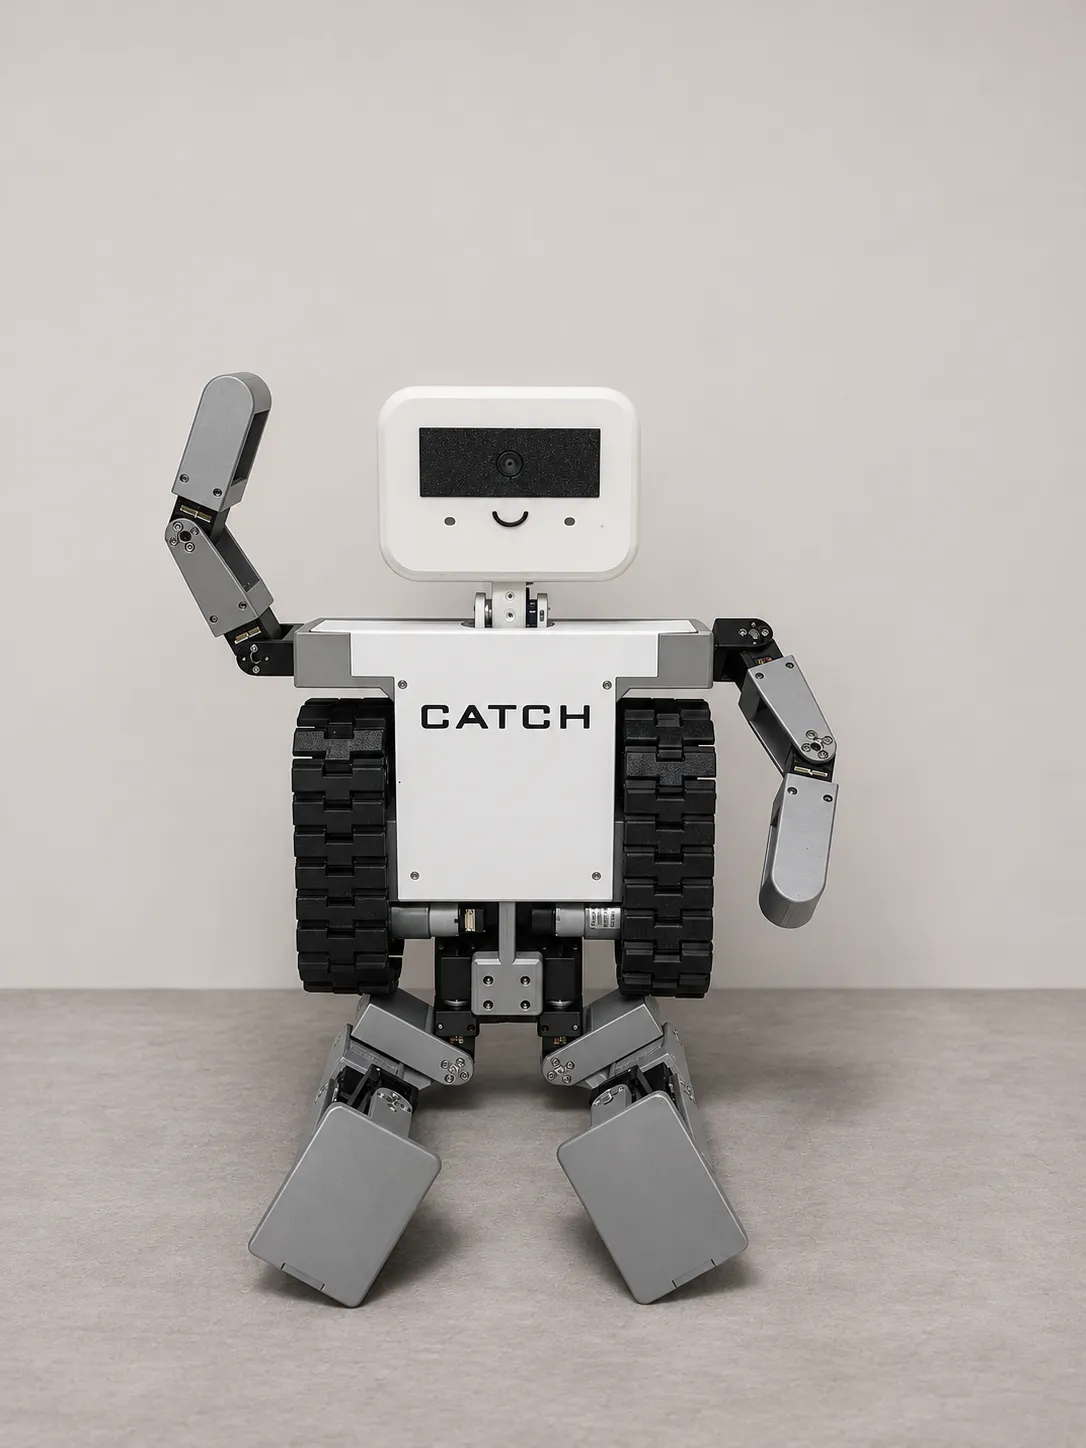
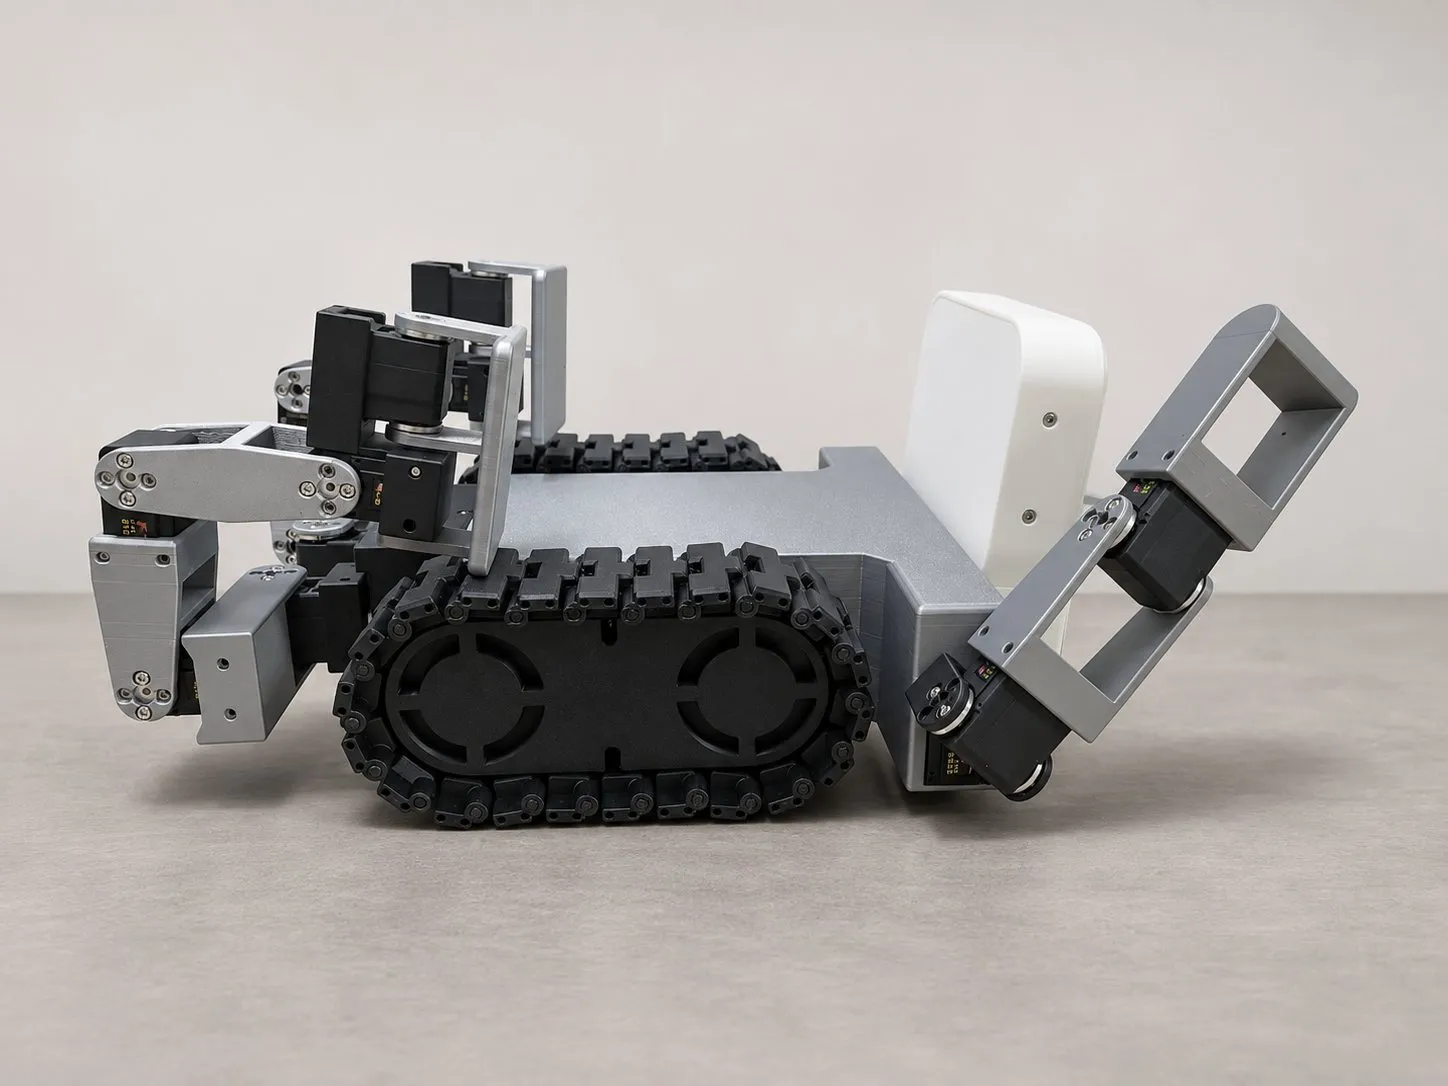
CATCH, my current project, sitting upright and folded into tracked mode. Watch the progress video
Projects
- What CATCH stands for, illustrated with prototype photos and CAD poses, followed by its exploded assembly, torso electronics, and wiring map.
CATCH
One small body designed to change shape with the task: folded low on its tracks to travel, or upright to reach out and interact with its arms and legs. I designed it in CAD, 3D printed it, and assembled it; the wiring is fully planned but not yet built.
Built · Not yet powered on
- Time-lapse of the WORM robot crawling forward step by step.
WORM
A worm-inspired colonoscopy robot that crawls through the colon by switching its adhesive pads between gripping and slipping. I led its hardware design, prototyping, and control, using an adhesive from a collaborating materials lab.
Tested ex vivo · Manuscript under review
- Gyecko crawling through a clear pipe, seen from above.
Gyecko
A 241 g gecko-inspired robot that inspects pipes from the inside, turning at a center joint to follow bends and stepping on stamp-type feet with sticky pads. Built by a team of six that I led, it crawled autonomously through dry, wet, and 30° inclined pipes, detecting obstacles along the way.
Built · Tested
- A simulated Unitree Go2 climbing and descending a series of high steps, including the final landing.
Go2 Extreme Parkour
A PPO-based perceptive locomotion framework for the Unitree Go2, and a study of how terrain information should reach the Actor and the Critic. In simulation, the best configuration crosses 80 cm gaps and climbs 45 cm parkour steps.
Simulation
Publications
A strain-triggered pseudo-gel transition for instantaneous and reversible adhesion switching
Design and Implementation of AI Machine Vision Inspection System with Multi-Optical Images for OLED Film Manufacturing
Experience
- 2026–CATCH · Independent project
- 2025–FineVT · Robotics & ML Researcher, alternative military service
- 2025–26LAIR, Sungkyunkwan University · Research Intern
- 2024–25AMRL, Sungkyunkwan University · Undergraduate Researcher
- 2024Dynamic Robotics Systems Lab, Seoul National University · Undergraduate Researcher
- 2023AIDIN · Intern, Sensor Development Team
- 2021–25Sungkyunkwan University · B.S. Mechanical Engineering, summa cum laude, ranked 1st of 186